
alnwlsn has used a pair of Teensy boards to take control of a robot arm that they recovered from surplus.
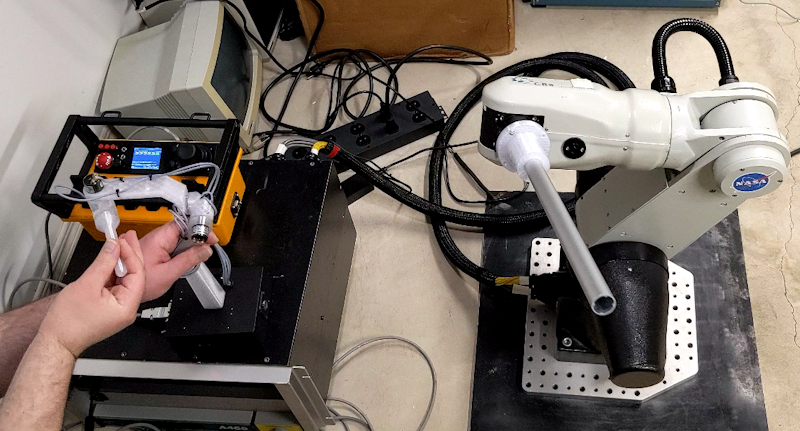
The 70lb lab-grade arm came with no software, but was still in running order. Instead of an FPGA, alnwlsn choose the powerful Teensy 4.1 to replace the embedded 486, FPGAs, and DSP chips that controlled the original. The main control loop is handled via IntervalTimer, which runs PID controllers, reads encoders, and writes to motors.
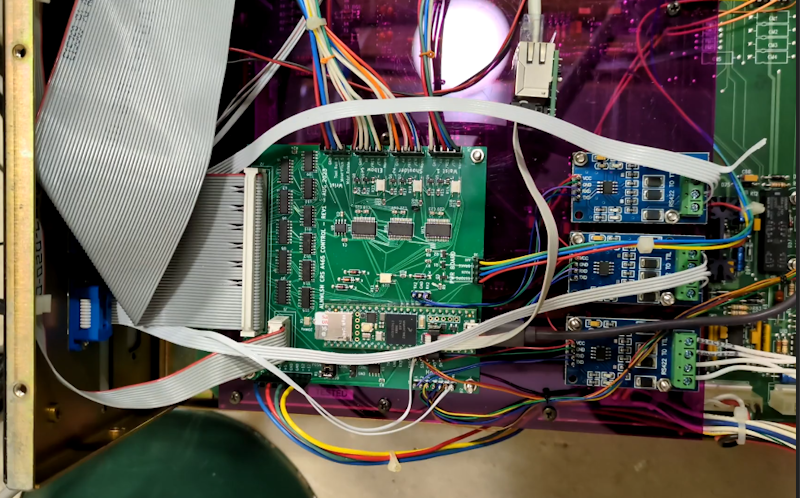
A custom PCB provides DACs for the ±10V analog signals required by the motor amps. A surplus control box refitted with a Teensy 3.2 provides manual control, and a mini reproduction of the main arm enables mimicry of its manipulation by the larger unit. 16MB of PSRAM allows several minutes of motion recording and playback, and the SD card stores encoder positions between reboots, to prevent the need for calibration each time. alnwlsn says that almost every pin on the Teensy is used for something, and you can see them in use in the video below!